Supervised Autonomous Robotics
Research into perception, planning and control for autonomous platforms, tested in simulation with explicit human intervention boundaries. No autonomy level is claimed.
005 — Robotics
Research into perception, planning and control for industrial automation and autonomous platforms, with human supervision and stated evidence gates.
Part of the Helios Autonomy program
Artificial intelligence work described here is research-stage. Figures are engineering targets measured under controlled conditions, not validated benchmarks. Nothing on this page is a delivered product, and no commercial availability is stated or implied.
Robotics research directions under the Helios Autonomy program, each with stated evidence gates and human supervision
Research into perception, planning and control for autonomous platforms, tested in simulation with explicit human intervention boundaries. No autonomy level is claimed.
Smart manufacturing systems in development with predictive maintenance, real-time optimization, and efficiency improvement targets across production lines.
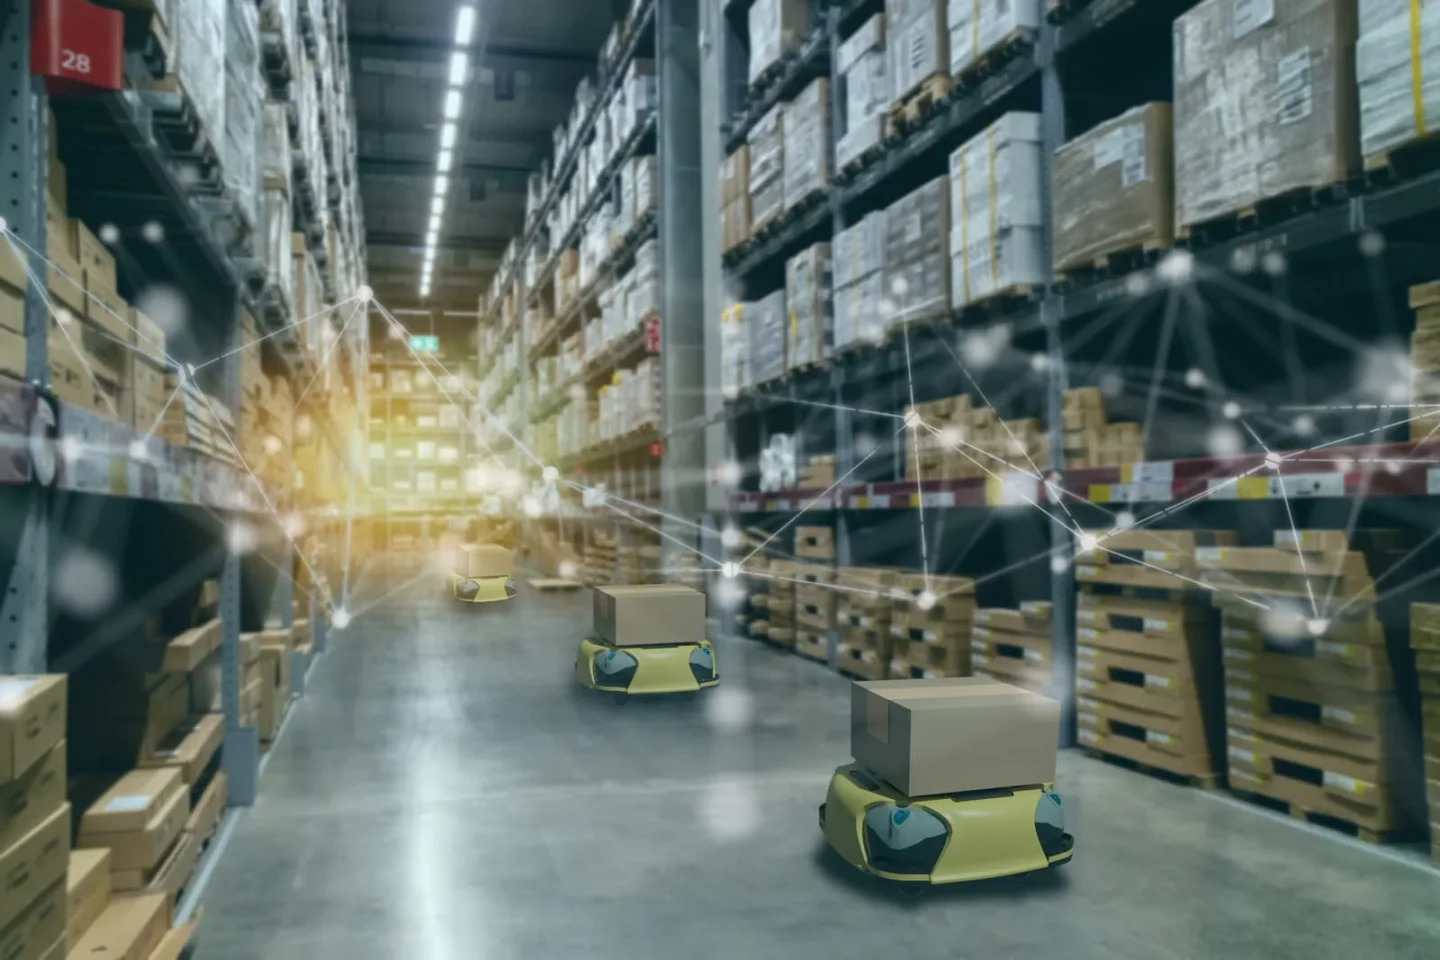
Human-safe cobots in development for warehouse, medical, and service applications with adaptive learning and continuous operation capabilities.
Centralized AI control in development for multi-robot coordination, predictive scheduling, and resource optimization across diverse robotic systems.
Continue with purpose
Enter through the work: review the flagship workflow, inspect the evidence, define a bounded partnership, or explore where you could contribute.
See how Planckchron is designing evidence-heavy workflows around human authority, traceability, and bounded deployment.
Review maturity labels, disclosed evidence, limitations, and public-claim boundaries.
Begin with a specific problem, measurable outcome, and accountable validation plan.
Explore careers, internships, and the disciplines shaping Planckchron’s research portfolio.